Rigging scorpion or spider legs with Rigify?
I have been using rigify for a few months now with overall sastifation, it handles 90% of my projects. this is the strange 10%. Im currently working on a scorpion,but there’s a problem. the legs for this model have 6 points or articulation, every leg type that rigify has currently cant reach that many bones. my only solution has been to use the finger rig type since it doesnt (as far as i know ) have a bone limit, but its not perfect. I was hopping to request a rig type that can handle 6 or more joints in a limb for insects like creatures.
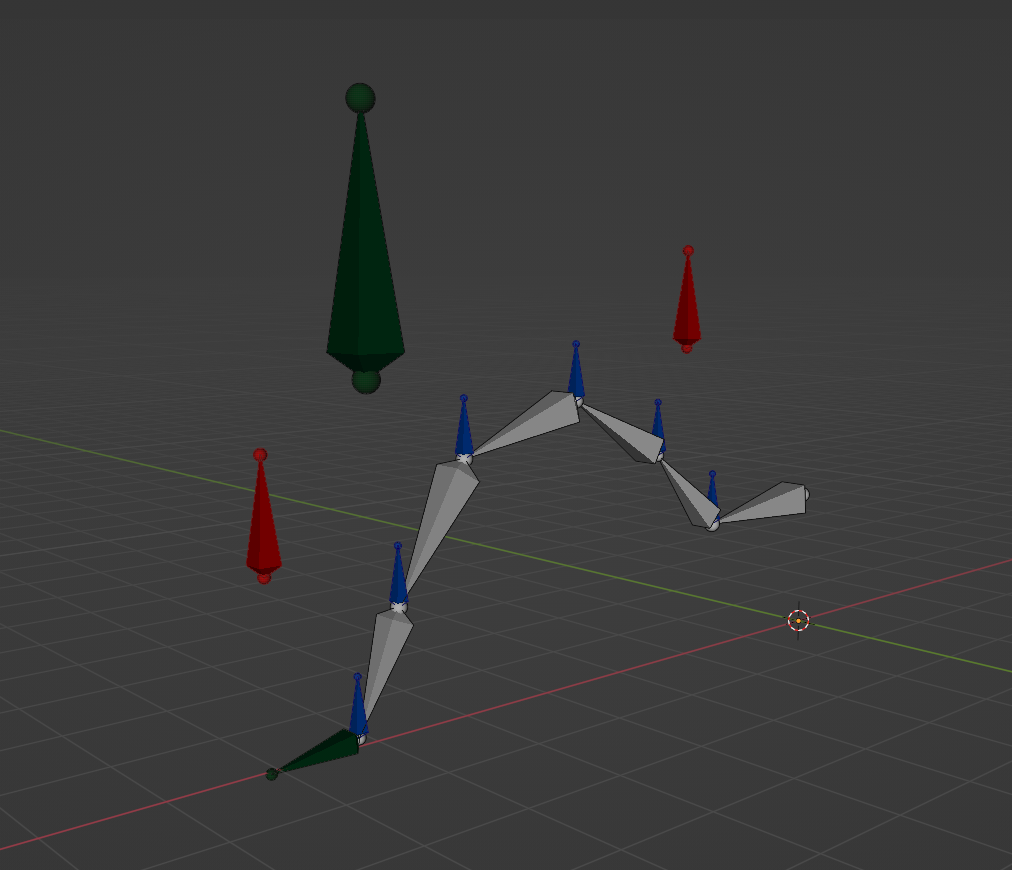
Edit:Here's how I think the "Insect limb" rig type would work. We can use the finger rig type as a base for the code, add tip ik pivot controls, add a pole target (green bones). As for controlling the bends of each limb joint, we can use IK stiffness, and add controllers for each bone or each pair of bones. The rig type could ask the rig maker if they would like to control 1-3 axis of stiffness and the option to limit axises
, as well as options for if they want pole targets or foot controllers. Furthermore, we can split the controls into functions, similar to that of the face rig. A few large controllers to block chunks of bends(Red bones), and multiple smaller controllers for each individual bend(Blue bones). with versitile ik features, as well as fk snapping and switching,what this leaves us is a limb rig type that has no bone limit, but lots of control.
9 Comments
I would use
spine.basic_taillike this:Or, if you want IK, keep the leg setup but with more segments that you can tweak:
IK doesn't really perform well beyond two-bones chains, so I guess it would be hard to make a "generic limb system that can go beyond 2 bones". 🤔
Im afraid either wont be suitible for the animator. the tail rig type here has no IK, so walking would be a massive pain to block out when trying to drive 6 controllers instead of one. as for the limb segments, those would morp and distort the leg, so it would not work here either. also, the paw rig type has more that 2 bones in its leg for ik usage, and its still usable.
I understand. I'm trying to communicate that, the solution is probably not just to make a longer IK chain.
I might be wrong on this, but I doubt a dev would see this post and decide out of the blue to spend time researching what even is a scorpion or arachnid leg and what could be done to rig them properly - if they are even compatible - and make a module for it that can be easily used and adapted to most models it could be used on. Gotta help the post a bit to get more chances to see it implemented 😉
The paw module is basically is a two-bone IK, but with a layer of FK controller inside the latest bone, so to speak. You can see how it works by looking at the MCH bones layer:
Most of the IK finger systems I have seen are very similar, in that the IK is actually on just two of the three phalanges, or that the IK is applied on two bones, and two phalanges are parented to one of these bones with a layer of extra movement on top of it.
You can make long IK chains, but IK (at least the solvers we have in Blender and other softwares I've rigged on) doesn't really give good results past 2 bones length. You will lack control over the bones within the chain. They will basically act as a 2-bones IK.
You can try it out yourself:
DemoIK.blend
I'm not an expert in arachnids and scorpions, but if I had to animate them, I wouldn't want such a rig.
At a glance, what I would want to animate this leg would look like this:
To give you an idea, this is a rig setup someone made to make a 2-jointed "IK setup":
Source: animation - How to rig an IK leg with 2 knee joints (Animal Leg Rigging) - Blender Stack Exchange
There are probably other better ways to make a rig that allows a nice control over such a limb.
but doesnt this prove my point that there should be something native to rigify? if the rig maker has to go out of their way to make a custom set up for an addon that was designed to save time for building rigs, why shouldnt there be a rig type for these type legs?
Yes, but as i explained above: if you want the change to happen, you probably need to elaborate your feature proposal 😉
trying to make a leg with this many bends with a single IK chain will not provide good results. To address this, I'd like to point out what the Paw rig type was able to accomplise. it uses multiple IK controllers to help animators drive the leg bends, a shin controller, a foot controller, and a heel controller. I'd say the only thing this new "insect" rig type has to do is replicat the concept of the paw rig type, but be able to handle more than 5 bends in the leg. this can be done by haveing multiple ik chains per limb, each featuring fk IK snapping and switching, as well as pole targets per bend.
(I've had to add an image to the original post since I couldnt figure out how to add one to a comment)
But that's the thing, the paw rig is still basically a 2-bone IK. How would you handle the extra bends? And how many should it be able to handle at max?
this is a maya tutorial that talks about creating an "attribute" to handle the control for its bend. most of it went over my head so im going to re watch it in the morning, but it seems to be a step in the right direrction. youtube.com/watch
Edit: ok so this is kinda cool. while we are in ik mode, the bend is controlled by bone rotation on a specified axis. the foot would still drive the leg and its bends, but each individual bend could have a rotation controller.
this could also mean that it could be limitless with how many bones the rig maker creates, as long as there are complete bends in the limb.